

Product Description
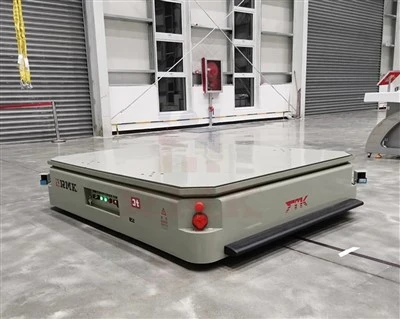
The laser SLAM AGV navigates by scanning the workshop with a LiDAR and building its own environment map, localizing against the natural outlines of walls, equipment and pillars with no magnetic strip, no QR sticker, no reflector and no rail. On the first run the vehicle is driven manually through the workshop to record the global map, and afterward it positions itself continuously while detecting temporary obstacles, people and stacked material in real time, slowing, detouring or stopping as needed. Dynamic algorithm correction keeps docking repeatable at lines, robots, machine tending stations, storage positions and lifting equipment, so precision electronics, fragile goods, appearance parts and heavy frames move without drift. It works around the clock regardless of light or light dust, and needs no maintenance of landmarks that wear, soil or shift. Dozens of vehicles can run online with automatic route allocation, intersection interlock and optimal task matching, and the fleet handles order receiving, delivery, return, standby, auto-recharge and self-diagnosis without a dedicated crew.
SLAM stability stands or falls on how many fixed environmental features the workshop offers, so our engineers evaluate your workshop layout up front and point out areas with too few stable features, the places where map drift would otherwise appear months after deployment. Because nothing is fixed to the floor, route and station changes are done at a PC and larger environment changes are recovered by a quick local re-mapping, which suits production that keeps iterating line by line. With no markers to inspect, clean or replace, the vehicles also remove the recurring maintenance labor that floor-guided fleets carry, and the auto-recharge and self-diagnosis functions let the fleet run as one unattended flow together with our pallet magazines and robots.
Specifications
|
Parameter |
Specification |
|
Navigation Method |
Laser SLAM natural navigation, marker-free |
|
Localization Principle |
LiDAR real-time scanning, self-built map with dynamic algorithm correction |
|
Floor Works |
Zero floor works of any kind |
|
Mapping |
First-run manual walk-through global mapping; local re-mapping available after major layout changes |
|
Control Mode |
Automatic scheduling plus manual mapping and debugging mode |
|
Autonomous Behavior |
Real-time obstacle detection with automatic deceleration, detour and stop |
|
Multi-Vehicle Operation |
Up to dozens of online vehicles; automatic route allocation, intersection interlock and task matching |
|
Power Supply |
Onboard rechargeable battery with auto-recharge support |
|
Unmanned Functions |
Auto order dispatch, delivery, return, standby and self-diagnosis |
Applications
Application 1
High-mix, low-volume smart factories that re-arrange lines often - new routes are drawn in software with zero hardware installation whenever the process changes.
Application 2
Clean rooms and high-standard plants with zero-floor-infrastructure goals - no strip, sticker or reflector is ever installed or serviced.
Application 3
Complex multi-zone intra-plant logistics connecting magazines, robot cells, CNC machines and warehouse buffer areas - the fleet takes the whole-plant flow from receiving to shipping as one scheduling problem.
Customization
- Platform dimensions, payload rating and locating fixtures are adapted from our own designs.
- Route planning and station configuration built around your workshop environment.
- Signal interlock for docking with pallet magazines, robots and CNC machines.
- Multi-vehicle scheduling and upper-level warehouse system interface.
- ODM only: appearance, structure and electrical control configuration are adjusted to your process requirements.
Packaging & Transportation
The main unit is wrapped in anti-scratch plastic film, the LiDAR, sensors and battery are packed in heavy-duty shock-resistant cartons, and the whole machine is fixed inside an export wooden crate. A pre-shipment mapping, navigation and docking function test is completed for every unit, and 100% comprehensive inspection is performed before packing. EXW, FOB and DDP terms are supported, settled mainly in USD; standard orders use 50% deposit and 50% before shipment, customized equipment 70% and 30%. A 12-month warranty with lifetime technical support applies.
FAQ
Q1. What environment does SLAM navigation require?
A1. The workshop must provide enough stable static features, such as walls, fixed machines and pillars. Frequent large-scale changes to the surrounding layout will affect map stability, and the affected area can be re-mapped locally to restore operation.
Q2. Can I add more AGVs later when capacity grows?
A2. Yes. The multi-vehicle scheduling system supports adding vehicles later, scaling from a single delivery loop to whole-plant fleet operation.
Q3. What is the MOQ and sample policy?
A3. Standard AGV orders start from 1 set. Samples can be made at actual cost, higher than mass production, free samples are not available, and different models can be combined in one order.
Hot Tags: laser slam agv, China laser slam agv manufacturers, suppliers, factory, Dual Rail RGV, laser guided free roaming cart, Laser Reflector Guided AGV, laser slam trackless agv, pallet handling agv, rail guided vehicle equipment